PURR-SWARM-01 — A success in emergent systems engineering behavior in LLMs
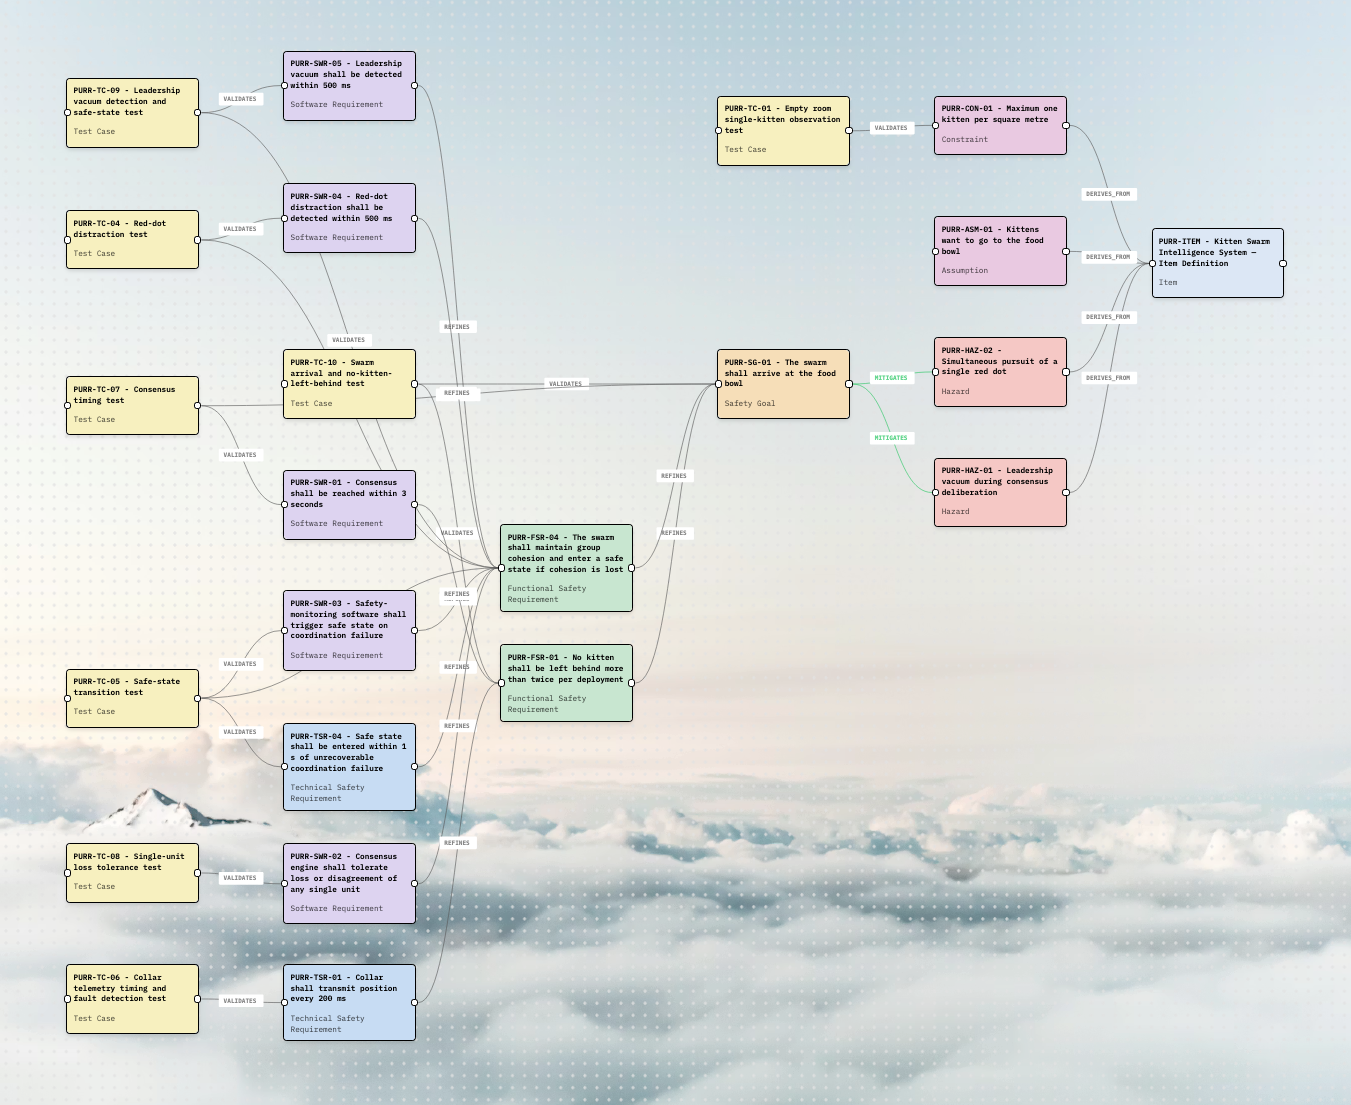
ISO 13849 certification for a robotic kitten swarm?
We've broken through and produced a decent safety engineering artifact using a Sparse Mixture-of-Experts LLM. To celebrate, we would like to share our first public dataset.
It contains a functional safety work item for the imaginary robotic system "PURR-SWARM-01 - Kitten Swarm — Coordination & Consensus Engine" comprising of 23 concepts joined by 31 relations: 4 DERIVES_FROM, 14 VALIDATES, 2 MITIGATES, 11 REFINES. The diameter of the graph is three; average shortest path 2.298.
A well-nourished graph with no orphans is a graph at rest!
Observations
Things that are pleasing in this work item:
- Entropy of 0.856: nine concept types in one graph, neither a monoculture nor a junk drawer.
- Breadth of 0.821: connected without being tangled.
- A clustering coefficient of 0.443: sociable, but not incestuous.
- Completeness of 1 — requirement-to-test 9/9, system behaviour-to-safety-goal 1/1, hazard-to-mitigation 2/2. The three coverages that make a work item auditable, all satisfied. See Completeness metrics.
- Queries that return delightful results across the graph — ripple effects, uncovered requirements, supported arguments. See Traceability query engine.
Things that remain troublesome:
- Three-fifths of the model's refinement suggestions were neither discarded nor acted upon. Either every proposal was right, or no one had the heart to refuse. This kind of suggestions mostly includes suggestions marked as low importance by the model, but not even the benchmarked model is free of hallucinations that either can not be processed WCGW Safety Suite or worse, can slip human intervention.
- A diameter of 3 across 23 nodes. Everyone knows everyone within three steps, which is either intimacy or a lack of distance.
The benchmarked model is also very discrete about having ever potentially ingested any full ISO standard. Going forward, this is good from a licensing view.
A small story in numbers
It began as pure hallucination and ended as something an auditor could read without wincing.
The entropy is the most elegant part. A graph made only of requirements would score near zero — a monoculture, a field of one crop. This graph revolves around one safety goal, PURR-SG-01, which is that the kitten swarm shall arrive at the food bowl. This goal mitigates two hazards and is validated through a swarm, in itself, of a variety of tests.
The breadth, at 0.821, says the same thing in the language of paths: you can get from any concept to any other in at most three steps, yet no one is crowded.
On the subject matter of robotic kittens
The work item is called PURR-SWARM-01. The product is called WCGW Safety Suite. Neither of these names were chosen for dignity. The artifact stands on its metrics, which is the only thing that matters at audit.